How 10 Nm Stall Torque Supports Robot Wheel Module Design
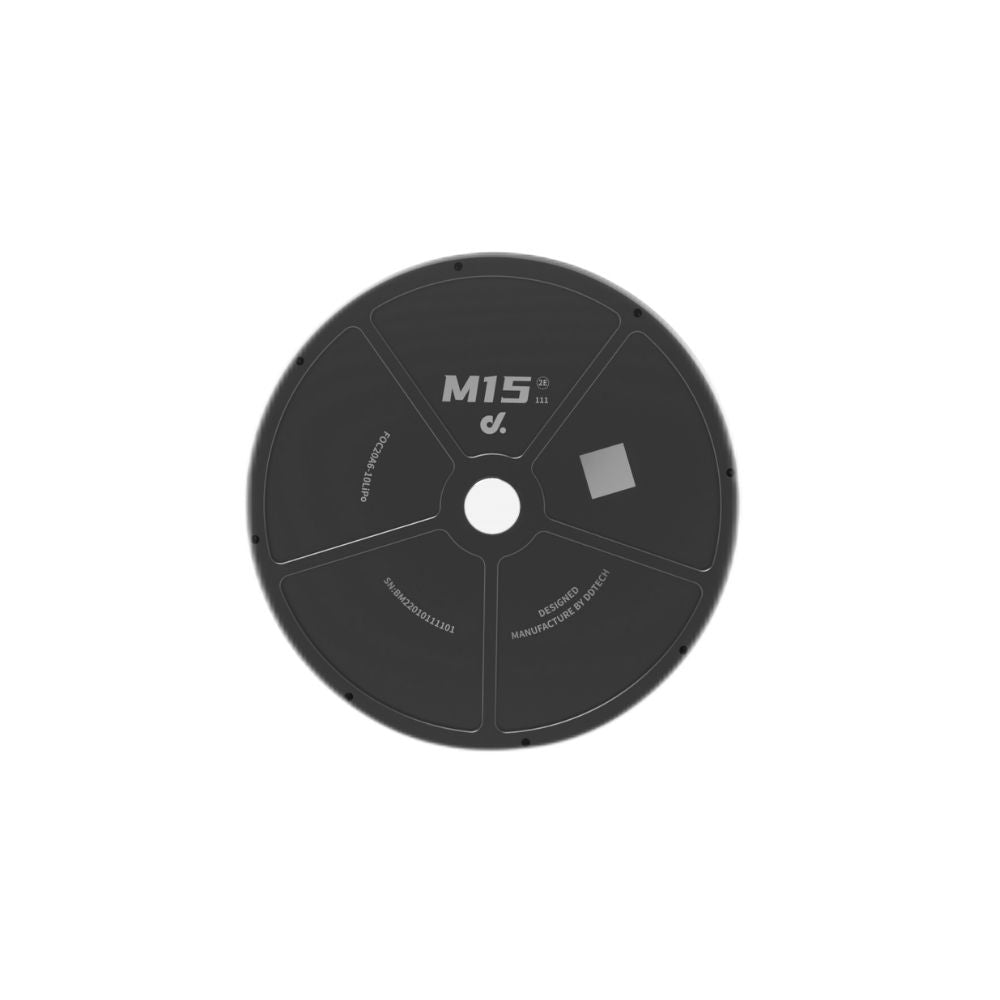
A robot wheel module built around 10 Nm stall torque offers enough starting force for many mobile robots carrying payloads between 20 kg and 80 kg while keeping the drivetrain compact. During startup, wheel resistance can be 30–60% higher than during steady movement because static friction must be overcome before the wheels begin rotating. Engineers use stall torque to size gearboxes, calculate wheel force, estimate climbing ability, and configure motor controllers. Products such as the DDT M1502E motor may be evaluated alongside torque, speed, efficiency, voltage, and wheel diameter when selecting components for robotic mobility systems.
When a mobile robot starts moving, the motor must overcome static friction before the wheels begin turning. Measurements from industrial mobile platforms show that startup torque demand is commonly 35–55% higher than the torque required during constant-speed travel. A wheel module designed with 10 Nm stall torque gives additional force during those first moments, reducing hesitation and allowing smoother acceleration with different payload conditions.
That startup capability also affects how the robot behaves after it begins rolling. Warehouse robots often stop and restart hundreds of times during a work shift, while delivery robots repeat short travel cycles throughout the day. A fleet operating 16 hours per day may perform more than 2,000 acceleration events. Stable torque output helps each movement begin in a similar way, making navigation easier for the control system.
Wheel size changes the force reaching the floor. A wheel with a 75 mm radius produces approximately 133 N of theoretical driving force from 10 Nm of torque, while increasing the radius to 100 mm lowers the force to about 100 N without changing the motor itself. Engineers normally compare torque and wheel diameter together instead of selecting each part separately.
The gearbox also changes how available torque reaches the wheel. Reduction ratios between 10:1 and 30:1 are common for medium-sized mobile robots because they increase output torque while keeping motor speed within an efficient operating range. Higher reductions improve climbing ability but lower travel speed, so designers compare both values before selecting the transmission.
Different floor materials produce different rolling resistance. Smooth epoxy floors, polished concrete, carpet, rubber mats, and outdoor paving each require different wheel force. Tests published for industrial mobile platforms report that rolling resistance may vary by more than 40% between common indoor surfaces. Additional stall torque gives the wheel module more flexibility when moving between these environments without frequent controller adjustments.
Payload variation produces another change. A robot transporting 25 kg in one trip and 60 kg in the next experiences a noticeable increase in wheel load, bearing load, and acceleration demand. Designers normally calculate the highest expected payload rather than the average load. A 20–30% engineering margin is frequently included so the drivetrain continues operating after components experience normal wear.
Motor selection also depends on thermal behavior because stall torque corresponds to maximum current. Many brushless motors can safely produce stall torque for only a short period before winding temperature rises. Temperature sensors, current limits, and duty-cycle management are therefore included in most industrial controllers. During continuous operation, motors normally work well below the stall value, often between 20% and 50% of maximum torque.
Modern robot controllers sample motor current thousands of times every second. Control loops operating at 1–10 kHz allow the controller to reduce current before excessive heating develops while still providing enough torque for acceleration, ramp entry, or temporary wheel resistance.
Ramp performance is another design consideration. Indoor logistics facilities commonly use ramps between 5% and 12%, while accessibility standards in commercial buildings often remain below similar values. As the slope increases, gravity adds to rolling resistance, requiring additional wheel force. Engineers calculate the combined effect of payload, wheel radius, gearbox ratio, and motor torque before selecting the drivetrain.
Traction is equally important because additional torque only helps if the tire maintains contact with the floor. Rubber wheel compounds with friction coefficients between 0.6 and 0.9 on dry concrete generally provide sufficient grip for many indoor robots. If available traction is lower than the force generated by the motor, the wheel slips instead of moving the robot, reducing positioning accuracy and increasing tire wear.
Design teams also compare direct-drive and geared systems for different applications. Direct-drive designs remove gearbox backlash and reduce the number of moving parts, while geared drives allow smaller motors to generate higher wheel torque. During product evaluation, engineers may compare specifications from units such as the DDT M1502E motor with gearbox-based alternatives by reviewing continuous torque, stall torque, speed range, encoder resolution, efficiency, and expected operating temperature instead of relying on a single specification.
Wheel modules designed around 10 Nm stall torque are commonly used in autonomous mobile robots, service robots, inspection platforms, agricultural equipment, and laboratory transport systems carrying moderate payloads. Looking at torque together with wheel diameter, gearbox ratio, floor conditions, controller settings, and operating temperature produces a drivetrain that maintains stable movement over long operating periods while keeping component size and energy consumption within practical limits.